🎙 Listen to a summary of this story
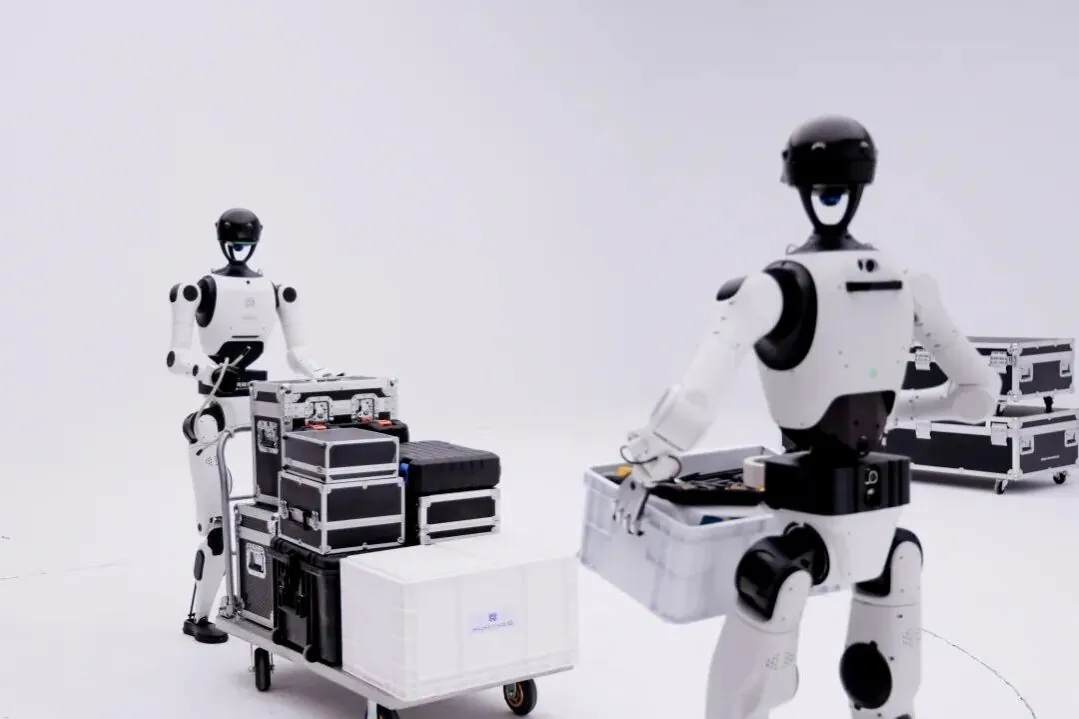
X-Humanoid unveiled an ambitious roadmap targeting a unified embodied model capable of self-evolving robot policies, marking a significant acceleration in autonomous robotics research. This strategy pivots on developing comprehensive world models that allow robots to learn complex tasks and adapt behaviors without constant human retraining.
The stated goal is to move beyond task-specific programming toward general-purpose robotic agents that can generalize across diverse environments and novel situations, mirroring higher levels of cognitive flexibility seen in biological systems. This pursuit positions X-Humanoid at the forefront of the shift from pre-programmed automation to truly intelligent, adaptive physical AI.
The underlying technical framework involves leveraging sophisticated simulation environments—such as Pelican's unifying world model simulator mentioned in the source material—to facilitate massive-scale training runs. This reliance on high-fidelity digital twins is critical for enabling robots to safely explore and learn from a near-infinite array of potential scenarios before physical deployment.
Technical Architecture and Development Focus
The core innovation lies in bridging the gap between large foundational models, typically trained in pure software, and their real-world actuation through robotic hardware. X-Humanoid’s roadmap details the integration of these learned policies directly into embodied systems capable of physical interaction.
This unified approach demands robust simulation capabilities; the Pelican simulator acts as a crucial intermediary, allowing researchers to rapidly iterate on policy refinement. By training in this simulated reality—where millions of interactions can occur virtually—the system minimizes the expensive and time-consuming process of trial-and-error on physical robots.
Furthermore, the emphasis on self-evolving policies suggests a move toward reinforcement learning architectures that possess intrinsic motivation or curiosity modules. The robot is not merely executing pre-defined goals but is actively seeking to improve its own understanding of the physics and affordances of its environment.
Broader Industry and Geopolitical Implications
The successful deployment of such unified, self-evolving robotic systems carries profound implications for industrial automation globally. It promises a transition from rigid assembly line robots to flexible partners capable of performing nuanced tasks in unpredictable settings, from logistics to elder care.
From a geopolitical standpoint, advancements in embodied AI are increasingly viewed as strategic national assets. China's push in this domain underscores the race among major technological powers to achieve genuine artificial general intelligence manifested physically, rather than purely computationally.
If X-Humanoid achieves its stated objectives—a truly generalist embodied model—it could drastically compress the timeline for widespread real-world adoption of sophisticated robotics. This capability would unlock new economic paradigms across manufacturing and service sectors that currently require extensive human intervention or highly specialized, brittle automation solutions.